M12 Lenses for Mobile Robotics

Compact M12 lenses for autonomous mobile robots, AGVs, and service robots. Wide-angle and low-distortion optics for SLAM, obstacle avoidance, and stereo depth.

Your robot's vision system is only as good as the lens in front of the sensor. The robotics collection gathers the M12 lenses suited to this work: wide-angle for navigation, low-distortion for SLAM feature tracking, and IP67-sealed for builds that seal at the lens. All ship same-day from San Diego.

1.8–7.2mm EFL Range
48°–215° FOV Range
Same Day US Shipping
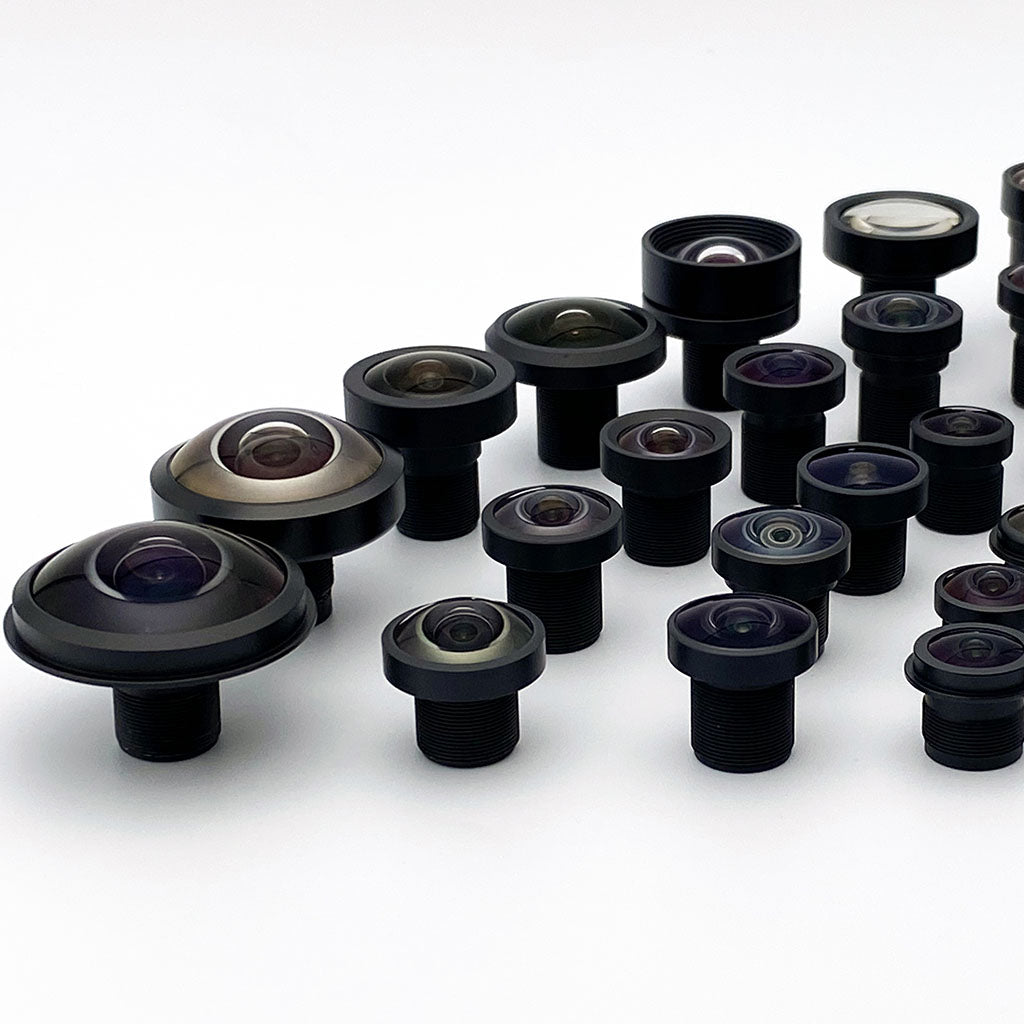
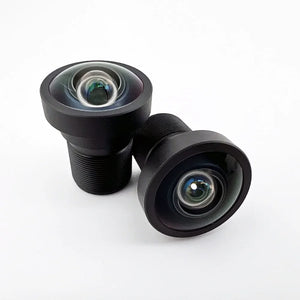
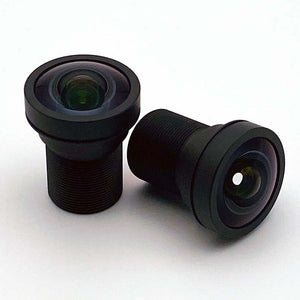
M12 lenses for mobile robotics — wide angle and low distortion S-mount lenses for AMR navigation

Lenses by robotics application

The right lens depends on what your robot needs to see. Here's how to narrow it down.

SLAM and visual navigation

SLAM systems need consistent, low-distortion images for feature extraction and pose estimation. Less distortion means less compute spent on correction.

Obstacle avoidance

You want maximum coverage with no blind spots. Fisheye lenses (180°–215° FOV) give your robot peripheral vision for path planning.

Stereo depth perception

Matched lens pairs for 3D reconstruction. Matched EFL and low distortion keep the two views overlapping and consistent; per-camera calibration absorbs residual differences.

Warehouse and logistics AMRs

Controlled lighting, but narrow aisles and unpredictable obstacles: people, forklifts, stray pallets.

Outdoor and all-weather robots

Delivery bots, ag rovers, patrol units. Rain, dust, temperature swings. Outdoors the water and dust path has to be sealed somewhere: either at the lens with a rated design, or around a standard lens with a qualified window and housing.

Low-light and IR navigation

Night operation or dim warehouses. Fast apertures (F/1.5–F/1.9) and IR-compatible optics for structured light or ToF illumination.

Popular picks for robotics teams

These are the lenses our robotics customers order most. All in stock, ships today.

Basler Dart Camera IP67 M12 Lens

Low Distortion 3.2mm M12 Lens

$39.00

Download .STPView Product
6mm M12 Lenses S Mount Lens

Low Distortion 6mm M12 Lens

$49.00

Download .STPView Product
No Distortion Wide Angle M12 Lens

Low Distortion 1.8mm M12 Lens

$39.00

Download .STPView Product
Wide Angle M12 Lens

Wide-Angle 4.5mm M12 Lens

$49.00

Download .STPView Product
Low Distortion 4.2mm M12 Lens

Low Distortion 4.2mm M12 Lens

$49.00

Download .STPView Product
IR Corrected 12mm M12 Lens

IR Corrected 12mm M12 Lens

$59.00

Download .STPView Product
3.5mm M12 Lens for IMX226 AR0821 IMX537

Large Format 3.5mm M12 Lens

$29.00

Download .STPView Product
3mm Wide-Angle M12 Lens

Wide-Angle 2.7mm M12 Lens

$39.00

Download .STPView Product

Browse Camera Lenses for Robotics

Quick spec comparison

Side-by-side specs for the lenses robotics engineers ask about most

Lens EFL FOV Distortion (metric stated) F# Sensor IP Rating Best For Price
CIL023 2.2mm 121° -5% TV (4:3) F/2.2 up to 1/2.3" SLAM navigation $39
CIL034 See product page 102° ~0%, metric not stated F/2.3–F/4.2 up to 1/1.8" IP67 Outdoor robots $39
CIL059 5.9mm 76° -4% rectilinear @ 8.8mm F/1.7–F/5.6 up to 1/1.7" IP67 option Stereo depth $49
CIL061 6mm 66° -8% / -5% TV F/1.9 up to 1/2.5" IP69K (B variant) Low light $39
CIL220 1.8mm 215° 0% F-theta residual (not rectilinear) F/2.3 2–5MP, 1/1.7" IP67 Obstacle avoidance $39
CIL327 2.7mm 169° -13% F-theta @ 7.1mm F/1.5 / F/1.8 up to 1/2.6" Short-range depth $39
CIL344 4.5mm 125° -3% F-theta @ 11.0mm F/1.9 / F/2.7 up to 2/3" IP69K (B variant) Warehouse AMR $49
CIL872 7.2mm 48° <1% TV F/2.8 1/2" Label reading $29

FOV values are each lens's full-image-circle figure from its product page; the field of view on your sensor is smaller when the sensor is smaller than the image circle. Verify your pairing with the FOV calculator and the sensor size chart.

The distortion column holds three different metrics, so read the label before you compare rows. TV distortion is a picture-height deviation measured on the stated aspect ratio. Rectilinear distortion is a radial departure from the ideal rectilinear mapping at the stated image circle. F-theta residual is the departure from a constant-angle-per-millimeter fisheye mapping, so the CIL220's 0% figure means its projection tracks that mapping, not that straight lines image straight. Negative is barrel in each convention.

IP69K in the rating column is the industry shorthand for ISO 20653 IP6K9K; IP67 is tested separately under IEC 60529.

How to pick an M12 lens for your robot

It comes down to three things: field of view, distortion, and aperture. They trade off against each other, and the right balance depends on what your robot's cameras actually need to do.

Field of view: coverage vs. resolution

Wider FOV means more spatial coverage but less angular resolution per pixel. For obstacle avoidance, coverage wins: a 215° fisheye kills blind spots, though it introduces heavy barrel distortion. For SLAM feature tracking, a 6mm low-distortion lens gives you cleaner feature correspondence over a narrower view. A lot of production robots run both: fisheye for surround awareness, rectilinear for the primary nav direction.

You can calculate your required FOV with our FOV calculator, or work backward from a target angle using the EFL calculator.

Distortion: what your algorithm can handle

Optical distortion reaches your vision pipeline through the camera model. ORB-SLAM, VINS-Mono, and similar systems work from a calibrated model, so what matters is how well that model fits your lens out to the corners, not whether the number clears a particular percentage. No universal threshold exists. Correction is cheaper than its reputation too: a precomputed remap runs fast on a Jetson, and fisheye-native front ends skip rectification altogether.

If you want the least distortion for the model to absorb, the CIL034 is the flattest lens in this set at roughly 0%, though its product page does not state which distortion metric that figure uses. The CIL023 is the wide option at 2.2mm and -5% TV distortion on a 4:3 frame.

If your obstacle detection stack already handles fisheye models (OpenCV's fisheye module, for instance), a 190° fisheye can work well despite the distortion. The software corrects it; the lens gives you the widest possible view.

Aperture: light gathering vs. depth of field

Fast apertures let in more light, which matters in warehouses, parking garages, and dusk operation. The CIL327 (2.7mm, F/1.5) is the fastest lens in this set; at a standard field of view, the CIL059 (5.9mm, F/1.7) and the CIL061 (6mm, F/1.9) are the quick options. The catch: faster aperture means shallower depth of field. Objects at different distances won't all be sharp.

There is no single F-number that puts 30cm to infinity in focus. Hyperfocal distance falls out of focal length, F-number, and the circle of confusion you are willing to accept, and that last term follows your pixel pitch and how much edge blur the algorithm tolerates. A 2.7mm lens reaches a near hyperfocal at a much lower F-number than a 7.2mm lens does on the same sensor.

Run your own focal length, F-number, and sensor format through the DOF calculator, and treat the result as geometry rather than physics: stopping down buys less than the geometric depth suggests once diffraction takes over. We can send measured depth-of-field data for a given lens if the margin looks tight.

Environmental protection

A warehouse AMR probably needs no rated lens at all. A delivery robot in Seattle needs the sealing somewhere, and you choose where. Rain-exposed builds usually evaluate IP67 lenses that seal at the barrel first; skipping a window and housing becomes an architecture option, taken only after validating the installed assembly. A standard lens sitting behind a window that the housing already qualifies carries no IP code of its own, and that is often the cheaper answer. If your robot gets pressure-washed, ask us about IP6K9K (industry shorthand IP69K) options.

Read any rating narrowly. It applies to the tested lens variant in its mounted configuration under the standard's water and dust exposures (IEC 60529 for IP67, ISO 20653 for IP6K9K, which are separate tests under separate standards). It does not cover steam, detergents, repeated sanitation cycles, UV exposure, condensation inside the barrel, or the rest of the camera.

Sensor compatibility

Every M12 lens has an image circle. If it's smaller than your sensor diagonal, you get dark corners (vignetting). Common robotics sensor formats:

  • 1/4" (4.5mm diagonal) — the smallest common module format
  • 1/3" (6.0mm diagonal) — most common robotics format, wide lens selection
  • 1/2.7" (6.7mm diagonal) — a common low-light robotics format
  • 1/2" (8.0mm diagonal) — higher resolution applications

Full dimensions are in our CMOS sensor size reference. If you're not sure which sensor you have, send us the datasheet and we'll recommend a match.

Not sure which lens?

Send us your sensor datasheet and a description of what the robot does. We'll recommend a lens.

Contact Engineering

Common questions from robotics teams

What we get asked most when engineers are picking lenses for their robots

What focal length M12 lens is best for mobile robot navigation?

Most robots we work with use 2mm to 4.5mm focal lengths, which lands roughly between 100° and 125° of coverage depending on the sensor, and fisheye designs reach 215°. That's the sweet spot for navigation and obstacle avoidance. Stereo setups typically run 3mm to 6mm matched pairs for depth at 0.5m to 5m working distance.

The exact answer depends on your sensor format. Plug your numbers into the FOV calculator or work backward from a target angle with the EFL calculator.

Do I need a low-distortion or fisheye lens for my robot?

Depends on your algorithm and how it models the camera. SLAM and visual odometry (ORB-SLAM, VINS-Mono, RTAB-Map) all run on a calibrated camera model, so the question is how well that model fits your lens out to the corners, not whether distortion sits under some percentage. There is no universal threshold. Correction is also cheaper than its reputation: a precomputed remap runs fast on a Jetson, and fisheye-native front ends skip rectification altogether.

Obstacle avoidance and surround-view systems want coverage instead. Fisheye (180°–215° FOV) sees the most, and most current frameworks calibrate it in software.

A lot of production robots use both: fisheye for peripheral awareness, rectilinear for the primary direction.

What M12 lens specs matter for stereo vision on robots?

Matched EFL helps with field-of-view overlap, unit interchangeability, and consistent imagery across a fleet; per-camera intrinsic calibration handles left-right EFL differences. The depth accuracy budget comes from stable intrinsics, camera synchronization, distortion-model fit, and baseline metrology. We can supply matched pairs with individual MTF test reports.

Low distortion matters too, since barrel distortion has to be corrected before rectification. Low-distortion lenses like the CIL059 (-4% rectilinear at an 8.8mm image circle) simplify that step. Match the lens to the sensor format and pixel pitch rather than to a headline megapixel number: the global-shutter parts that show up most in stereo rigs are modest in pixel count, with the IMX296 at about 1.6MP and the AR0234 at about 2.3MP. Check that the image circle covers the format and that the chief ray angle suits the sensor's microlens profile.

Are these lenses compatible with NVIDIA Jetson and Raspberry Pi cameras?

Yes, with the usual checks. The thread is standard M12x0.5, so these lenses thread into the M12 holders on boards from e-con Systems, Leopard Imaging, ArduCam, FRAMOS, and others. Common Jetson sensors: IMX477, IMX327, AR0234. Thread alone is not fit, though. Check holder height against the lens back focal length, rear clearance behind the barrel, focus travel, image circle against the sensor diagonal, and chief ray angle against the sensor's microlens profile.

The Raspberry Pi HQ Camera ships in two official versions: on the C/CS-mount board an M12 lens needs an M12-to-CS adapter (we sell them in our accessories collection), and on the native M12-mount board, sold since January 2023, the lens threads straight into the holder.

The sensor size reference has the dimensions you need for the image circle check.

Can I get IP67 or IP69K lenses for outdoor robots?

Yes. Two sealed options sit in the stock catalog, and robots that see rain and dust usually begin their evaluation there: the CIL034 (a wide-angle IP67 design at roughly 0% distortion) and the CIL220 (215° fisheye, IP67, surround coverage). The rating certifies immersion testing on the mounted variant only, so validate the installed assembly against your actual exposure.

If your robot gets pressure-washed (food processing, ag), we can do IP6K9K (industry shorthand IP69K) as a custom option. We also offer hydrophobic coatings that shed rain droplets. IP ratings apply to the tested lens variant in its mounted configuration under the standard's water and dust exposures (IEC 60529 for IP67, ISO 20653 for IP6K9K); they do not cover steam, detergents, repeated sanitation cycles, or the rest of the camera. Reach out and we'll figure out what fits.

What's the minimum order quantity for robotics lens samples?

No minimum. Buy one lens, try it, see if it works. Samples ship same day if you order before 12 PM PT. When you're ready for production quantities (100+), volume pricing kicks in. We also do custom mods: filter integration, barrel changes, matched stereo pairs for fleet builds.

Need help picking a lens?

We work with robotics teams every day, from first prototype to fleet rollout. Single-lens samples ship same day. No minimum order.